When selecting a three-phase induction motor, one of the first specifications you may see is the number of poles: 2 pole, 4 pole, 6 pole or 8 pole.
![彩色工业电机,3D渲染隔离在白色背景]()
Motor pole count is important because it directly determines the synchronous speed of the rotating magnetic field. In practical terms, it is one of the main reasons one AC motor runs close to 3000 rpm while another motor of similar power runs close to 750 rpm on the same 50 Hz power supply.
However, motor poles are often misunderstood.
A higher pole count does not automatically mean that a motor is “stronger,” more efficient, or has better starting torque. Pole count primarily determines speed. Rated torque then depends on the relationship between motor power and actual shaft speed, while starting performance also depends on the complete electrical and mechanical motor design.
This guide explains what motor poles mean, compares 2-pole vs 4-pole vs 6-pole vs 8-pole motors, and shows how pole count affects speed, rated torque, motor size and industrial applications.
What Are Motor Poles?
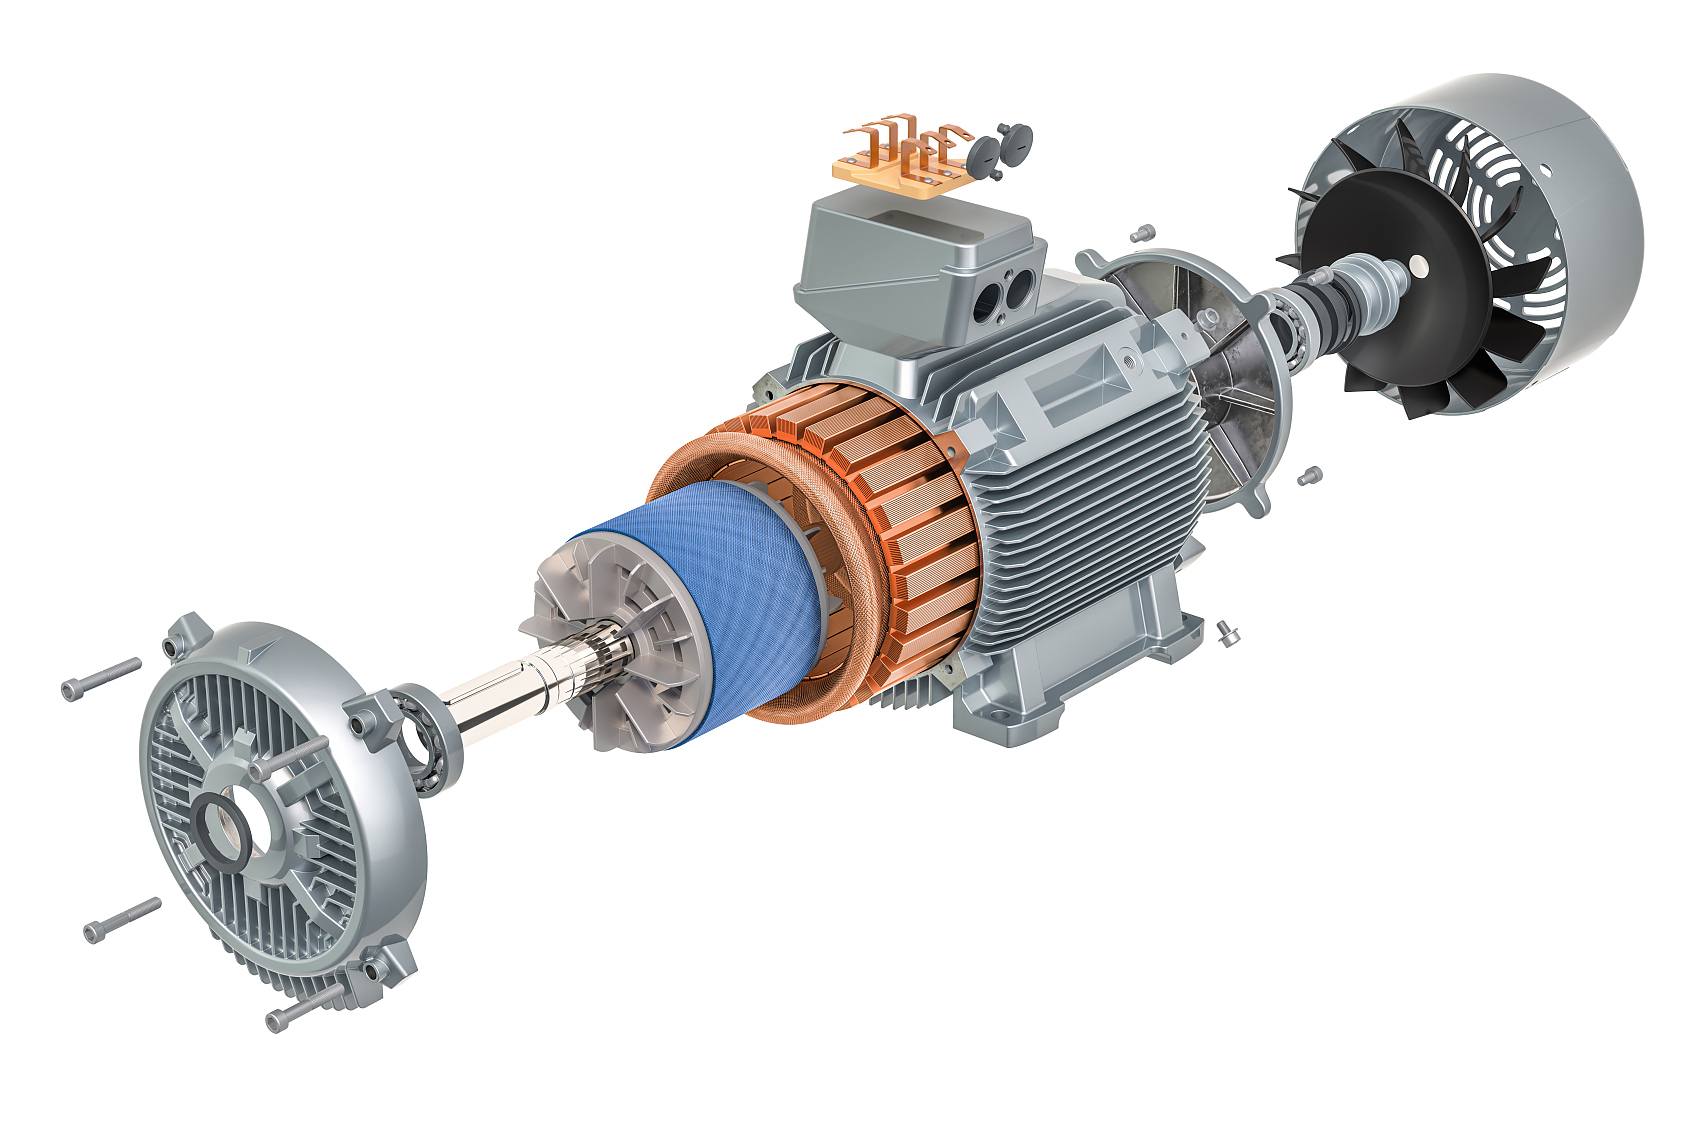
Motor poles are the magnetic north and south poles created by the stator winding of an AC motor.
When three-phase AC power is supplied to the stator, the windings create a rotating magnetic field. The speed of this magnetic field depends on two main factors:
Supply frequency
Number of magnetic poles
A motor with fewer poles has a faster rotating magnetic field. A motor with more poles has a slower rotating magnetic field.
![部分工业电机,3D渲染隔离在白色背景上]()
This is why a 2-pole motor runs much faster than an 8-pole motor when both operate at the same frequency.
How Motor Poles Affect Synchronous Speed
The theoretical rotating-field speed is called synchronous speed.
It can be calculated using:
Synchronous Speed (rpm) = 120 × Frequency (Hz) ÷ Number of Poles
For example, for a 50 Hz motor:
2 poles: 120 × 50 ÷ 2 = 3000 rpm
4 poles: 120 × 50 ÷ 4 = 1500 rpm
6 poles: 120 × 50 ÷ 6 = 1000 rpm
8 poles: 120 × 50 ÷ 8 = 750 rpm
At 60 Hz, the synchronous speeds become:
2 poles: 3600 rpm
4 poles: 1800 rpm
6 poles: 1200 rpm
8 poles: 900 rpm
This makes pole count one of the most important parameters when selecting an industrial AC motor.
2, 4, 6 and 8-Pole Motor Speed at 50Hz and 60Hz
The following table shows the relationship between pole count, frequency and typical motor speed.
| Motor Poles | 50Hz Synchronous Speed | Typical Rated Speed at 50Hz | 60Hz Synchronous Speed | Typical Rated Speed at 60Hz |
2 Pole | 3000 rpm | ~2850–2950 rpm | 3600 rpm | ~3450–3550 rpm |
4 Pole | 1500 rpm | ~1430–1470 rpm | 1800 rpm | ~1720–1770 rpm |
6 Pole | 1000 rpm | ~950–980 rpm | 1200 rpm | ~1140–1180 rpm |
8 Pole | 750 rpm | ~710–740 rpm | 900 rpm | ~850–890 rpm |
The exact rated speed varies according to motor power, efficiency class, rotor design, load and manufacturer.
Why Is Actual Motor Speed Lower Than Synchronous Speed?
A standard induction motor cannot normally operate exactly at synchronous speed.
The rotor needs to rotate slightly slower than the stator's magnetic field so that current can be induced into the rotor and torque can be produced.
The difference between synchronous speed and actual rotor speed is called slip.
For example, a 4-pole 50 Hz motor has:
Synchronous speed = 1500 rpm
but its nameplate may show:
Rated speed = 1450 rpm
That difference is normal for an induction motor.
Why Rated Speed Matters When Selecting Equipment
When calculating:
Pump speed
Fan speed
Gearbox output speed
Pulley speed
Conveyor speed
use the motor's rated speed, not only the theoretical synchronous speed.
This provides a more accurate result.
What Is the Difference Between 2, 4, 6 and 8-Pole Motors?
The main difference is operating speed, but the different speeds also affect motor torque, dimensions, noise, connected equipment and application suitability.
2-Pole Motor
A 2-pole motor has the highest standard rotational speed among common industrial induction motors.
Typical speeds are approximately:
2900 rpm at 50 Hz
3500 rpm at 60 Hz
Advantages of a 2-Pole Motor
A 2-pole motor is suitable when the driven equipment requires high rotational speed without an additional speed-increasing transmission.
Typical advantages include:
High shaft speed
Compact solution for high-speed equipment
Direct connection to many centrifugal loads
Widely available IEC configurations
Typical 2-Pole Motor Applications
Common applications include:
However, high rotational speed also increases the importance of rotor balance, bearing condition, vibration and correct alignment.
4-Pole Motor
A 4-pole motor is one of the most commonly used industrial motor configurations.
Typical rated speed is approximately:
1450 rpm at 50 Hz
1750 rpm at 60 Hz
It offers a practical speed range for a very wide range of industrial machines.
Why Are 4-Pole Motors So Common?
Many pumps, compressors, machinery drives and gearbox inputs are designed around approximately 1500 rpm at 50 Hz or 1800 rpm at 60 Hz.
A 4-pole motor therefore provides a good standard platform for:
Typical 4-Pole Motor Applications
Common applications include:
For industrial gearboxes in particular, a 4-pole motor around 1450 rpm is one of the most common input-speed configurations.
6-Pole Motor
A 6-pole motor operates at approximately:
960–980 rpm at 50 Hz
1150–1180 rpm at 60 Hz
It can be useful when the machine requires a lower direct-drive speed than a standard 4-pole motor.
When Does a 6-Pole Motor Make Sense?
A 6-pole motor may reduce or eliminate the need for additional mechanical speed reduction when the required equipment speed is relatively close to 1000 or 1200 rpm.
Typical 6-Pole Motor Applications
Possible applications include:
The final choice should depend on the required machine speed and load rather than selecting a 6-pole motor simply because a higher pole count is assumed to produce better torque.
8-Pole Motor
An 8-pole motor provides an even lower standard speed:
Where Are 8-Pole Motors Used?
8-pole motors are suitable when a relatively low direct-drive speed is required.
Typical Applications
Applications may include:
For applications requiring much lower speeds such as 20, 40 or 60 rpm, an 8-pole motor alone is usually not enough. A gearbox is normally required.
Does More Motor Poles Mean More Torque?
![11]()
This is one of the most important points to understand.
Pole count itself does not directly determine how much torque a motor can produce.
However, when motors have the same rated power, a lower rated speed means higher rated shaft torque.
Rated torque can be estimated with:
Torque (Nm) = 9550 × Power (kW) ÷ Rated Speed (rpm)
For example, consider four hypothetical 5.5 kW motors:
| Motor | Approx. Rated Speed | Approx. Rated Torque |
2 Pole | 2900 rpm | 18 Nm |
4 Pole | 1450 rpm | 36 Nm |
6 Pole | 970 rpm | 54 Nm |
8 Pole | 730 rpm | 72 Nm |
This demonstrates why higher-pole motors of the same rated kW normally have higher rated shaft torque: their rated speed is lower.
Rated Torque Is Not the Same as Starting Torque
It is incorrect to assume:
More poles = automatically better starting torque.
Starting torque depends on factors including:
A correctly designed 4-pole motor may therefore have better starting characteristics for a particular machine than another 6- or 8-pole motor.
Check Starting Conditions Separately
For applications such as:
always confirm starting torque and load characteristics separately from pole count.
2-Pole vs 4-Pole Motor
The most common comparison is between 2-pole and 4-pole motors.
A 2-pole motor provides approximately twice the speed of a 4-pole motor at the same frequency.
At 50 Hz:
Which One Should You Choose?
Choose a 2-pole motor when the equipment requires higher direct speed, such as certain pumps and fans.
Choose a 4-pole motor when approximately 1450/1750 rpm is appropriate or when the motor will drive a gearbox.
Do not select based on speed alone. Check the driven equipment's rated speed, power requirement and torque curve.
4-Pole vs 6-Pole Motor
A 4-pole motor runs around 1450 rpm at 50 Hz, while a 6-pole motor runs around 970 rpm.
At the same motor power, the 6-pole motor has higher rated shaft torque because of the lower rated speed.
However, this does not mean a 6-pole motor is automatically the better choice for heavy equipment.
Selection Example
If a machine is designed for approximately 1450 rpm:
→ 4-pole is normally appropriate.
If it requires approximately 960 rpm direct drive:
→ 6-pole may be more suitable.
If it requires only 60 rpm:
→ Neither is suitable for direct drive; a gearbox is normally required.
6-Pole vs 8-Pole Motor
The main difference between 6-pole and 8-pole motors is again speed.
At 50 Hz:
6 pole: around 970 rpm
8 pole: around 730 rpm
An 8-pole motor of the same kW rating will have higher rated shaft torque because it operates more slowly.
But other considerations—including cost, frame size, efficiency, starting characteristics and availability—should also be considered.
Should You Use a High-Pole Motor or a 4-Pole Motor with a Gearbox?
This is particularly important for conveyors and mixing equipment.
A machine may require an output speed of only:
100 rpm
60 rpm
40 rpm
20 rpm
Choosing an 8-pole motor still does not reduce the speed enough.
In these applications, one common solution is:
4-pole motor + gear reducer
For example:
1450 rpm motor + 25:1 gearbox ≈ 58 rpm output speed
Advantages of Motor + Gearbox
A gearbox can provide:
Much lower output speed
Significant torque multiplication
Flexible gear ratios
Different output shaft directions
Compact mechanical integration
Applications
A 4-pole motor with a helical, worm or cycloidal gearbox is widely used for:
Therefore, choosing more poles is not always the best way to obtain low machine speed.
How Pole Count Affects Motor Efficiency
Motor efficiency is influenced by much more than pole count.
Important factors include:
Higher-pole motors are therefore not automatically more efficient than lower-pole motors.
IE2, IE3 and IE4 Motors
Efficiency classes such as IE2, IE3 and IE4 provide a much more useful basis for comparing motor energy performance.
When selecting an industrial motor, compare:
rather than assuming pole count alone determines energy consumption.
Motor Pole Count and VFD Operation
A Variable Frequency Drive changes motor speed by changing supply frequency.
It does not change the physical number of motor poles.
For example, a 4-pole motor remains a 4-pole motor when controlled by a VFD.
![暖房供暖设备的房间之一]()
VFD Speed Example
A 4-pole motor has a synchronous speed of:
1500 rpm at 50 Hz
1200 rpm at 40 Hz
900 rpm at 30 Hz
Actual induction motor speed remains slightly below these synchronous values.
Low-Speed Operation
Long-term low-frequency operation may reduce the cooling performance of a standard shaft-mounted fan.
For applications requiring continuous low-speed operation, consider:
Can One Motor Have More Than One Pole Configuration?
Yes.
Some motors are designed as two-speed or pole-changing motors.
They can change effective pole configuration through different winding connections.
Examples include:
2/4 pole
4/8 pole
4/2 pole
These motors are used where two fixed operating speeds are required without using a VFD.
However, a standard single-speed motor cannot simply switch from 4 poles to 6 poles through normal wiring changes.
How to Choose the Right Motor Pole Count
Start with the required speed of the driven machine.
Step 1: Confirm Required Machine Speed
Determine whether the equipment requires approximately:
Step 2: Confirm Frequency
The same pole count operates at different speeds on 50 Hz and 60 Hz systems.
Step 3: Check Motor Power
Calculate the motor power required by the machine.
Step 4: Check Rated and Starting Torque
Do not rely only on pole count.
Step 5: Determine Direct Drive or Gearbox Drive
If the equipment requires significantly lower speed, a standard 4-pole motor with a gearbox may provide a more flexible solution.
Step 6: Check Efficiency and Operating Conditions
Consider:
Motor Pole Selection by Application
Pumps
Centrifugal pumps commonly use 2-pole or 4-pole motors depending on the hydraulic design.
Always match the motor speed to the pump manufacturer's rated speed.
![燃气锅炉房管道上的发动机和网泵。]()
Fans and Blowers
2-pole and 4-pole motors are common, while larger low-speed fans may use 6- or 8-pole motors.
Conveyors
Most conveyors require much lower speeds than any direct-drive standard motor.
A common configuration is therefore:
4-pole motor + gearbox
The gearbox is selected according to conveyor speed, pulley diameter, load and required torque.
Mixers and Agitators
Some direct-drive mixers can use 6- or 8-pole motors.
However, many industrial mixers require very low impeller speeds and high shaft torque, making a 4-pole motor combined with a helical or cycloidal gearbox a common solution.
Compressors
The correct pole count depends on compressor design and rated input speed. Never replace one pole configuration with another without checking the compressor speed requirement.
Can You Replace a 4-Pole Motor with a 6-Pole Motor?
Not directly in most applications.
The mechanical installation may fit, but the speed will change significantly.
For example at 50 Hz:
4 pole ≈ 1450 rpm
6 pole ≈ 970 rpm
Replacing a 4-pole motor with a 6-pole motor could reduce machine speed by approximately one third.
This may change:
Pump flow
Fan airflow
Conveyor speed
Compressor performance
Machine output
Always confirm the driven equipment requirement before changing pole count.
How Victory Supports 2, 4, 6 and 8-Pole Motor Selection
Victory Machinery Technology Co., Ltd. supplies industrial induction motors for OEM equipment manufacturers, industrial distributors, maintenance companies and end users.
Victory can provide multiple pole configurations according to the required equipment speed and operating conditions.
![工厂里正在组装新的蓝色电动机]()
Available Industrial Motor Options
Depending on the project, Victory can provide:
2-pole three-phase motors
4-pole three-phase motors
6-pole three-phase motors
8-pole three-phase motors
IE2, IE3 and IE4 motor options
Brake motors
VFD-duty motors
Explosion-proof motors
Special voltage and frequency configurations
50Hz and 60Hz Motor Support
Motors can be selected according to local electrical systems, including common 50 Hz and 60 Hz configurations.
Voltage, frequency, connection, rated speed and current should be confirmed together rather than changing only one electrical parameter.
Motor and Gearbox Selection
Victory also supplies complete gear motor solutions.
![摆线卧式]()
For applications requiring very low speed and high torque, we can evaluate:
Motor pole count
Motor power
Gear ratio
Output speed
Output torque
Mounting arrangement
This helps determine whether a higher-pole direct-drive motor or a 4-pole motor with a gearbox is more suitable.
Replacement Motor Support
For motor replacement projects, provide:
Existing motor nameplate
Rated power
Voltage and frequency
Pole count or rated speed
Mounting method
Frame size
Shaft and flange dimensions
Driven equipment
Operating conditions
![半成品]()
The replacement motor should match both electrical performance and mechanical installation requirements.
FAQ About Motor Poles
What Does the Number of Poles Mean on a Motor?
Motor poles are the magnetic poles created by the stator winding. Pole count and supply frequency determine the synchronous speed of an AC motor.
Which Is Faster, a 2-Pole or 4-Pole Motor?
A 2-pole motor is approximately twice as fast as a 4-pole motor at the same frequency.
At 50 Hz, their synchronous speeds are 3000 and 1500 rpm respectively.
What Is the Speed of a 4-Pole Motor?
Synchronous speed is 1500 rpm at 50 Hz and 1800 rpm at 60 Hz. Actual rated speed is typically around 1450 and 1750 rpm because of induction motor slip.
Does an 8-Pole Motor Have More Torque Than a 4-Pole Motor?
If both motors have the same rated power, the lower-speed 8-pole motor will have higher rated shaft torque. However, pole count alone does not determine starting or maximum torque.
Does More Poles Mean Better Starting Torque?
Not necessarily. Starting torque depends on the complete motor design, voltage, rotor characteristics, starting method and load.
Can a VFD Change a 4-Pole Motor into a 6-Pole Motor?
No. A VFD changes supply frequency and therefore motor speed, but it does not change the physical pole configuration.
Which Pole Motor Is Best for a Conveyor?
Many conveyors use a 4-pole motor combined with a gearbox because the conveyor normally requires much lower speed and higher torque than a direct motor can provide.
Which Pole Motor Is Best for a Mixer?
It depends on required mixer speed. Some direct-drive mixers use 6- or 8-pole motors, while low-speed industrial mixers commonly use a 4-pole motor with a gearbox.
Can I Replace a 2-Pole Motor with a 4-Pole Motor?
Only if the driven machine can operate at approximately half the original speed. Motor power, frame, torque, shaft dimensions and application performance must also be checked.
Conclusion
Motor pole count primarily determines the synchronous speed of an AC motor.
At 50 Hz, common synchronous speeds are:
2 pole: 3000 rpm
4 pole: 1500 rpm
6 pole: 1000 rpm
8 pole: 750 rpm
At 60 Hz, they become:
2 pole: 3600 rpm
4 pole: 1800 rpm
6 pole: 1200 rpm
8 pole: 900 rpm
Actual induction motor speed is slightly lower because of slip.
For motors with the same rated power, lower speed results in higher rated shaft torque. However, pole count alone does not determine starting torque, efficiency or overall motor performance.
The correct motor should therefore be selected according to required machine speed, power, torque, frequency, duty and operating conditions.
For very low-speed equipment such as conveyors, mixers and feeders, using a 4-pole motor together with a correctly selected gearbox is often more practical than increasing the motor pole count alone.
Victory can support 2-, 4-, 6- and 8-pole motor selection, 50Hz and 60Hz configurations, replacement motors and complete motor-and-gearbox solutions according to the actual industrial application.